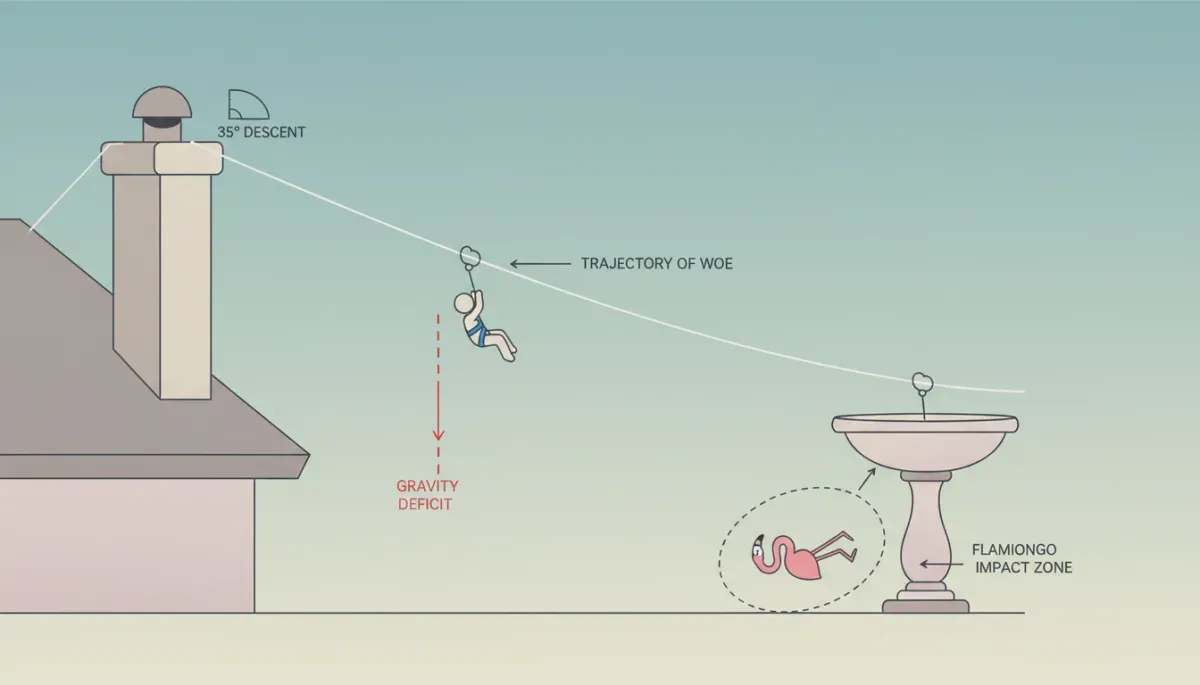
CASE FILE #117: THE GRAVITY-OPTIMIZED ZIP-LINE
The “Backyard Agile Descent Framework”
Recruitment occurred when Earl Gunderson pinged the cul‑de‑sac Slack with the subject line “ONE BRAVE SOUL NEEDED: gravity refactor.” Stevo, as usual, replied LGTM before reading the thread. The proposition promised “a continuous integration of backyard to birdbath” via DIY zip‑line anchored to Earl’s chimney with discount, humming carabiners (CHORD: synth F minor). During testing, Stevo achieved three uncontrolled deployments, a mid‑air 360° code review with a confused crow, and a brief, hovering SEGFAULT over Brenda’s hydrangeas (GRAVITY DEFICIT: +2). Landing was technically sideways but fully logged. Stevo rated the experience 8.7/10 for latency and snack proximity.
class ZipLineRun:
    def __init__(self, rider, anchor_strength):
        self.rider = rider
        self.anchor_strength = anchor_strength
        self.gravity_deficit = 2

    def execute(self):
        if self.anchor_strength < 1.0:
            return "UNSCHEDULED AERIAL SPRINT"
        return "CONTROLLED DESCENT (BETA)"

run = ZipLineRun("Stevo", anchor_strength=0.42)
result = run.execute()
⚡ SURVIVOR STATUS: Achieved stable horizontal position after colliding gently with three lawn flamingos and a recycling bin.
[LAB NOTE 0117]: For 48 hours post‑incident, Stevo’s socks accumulated static charge sufficient to reboot nearby smart doorbells on contact.
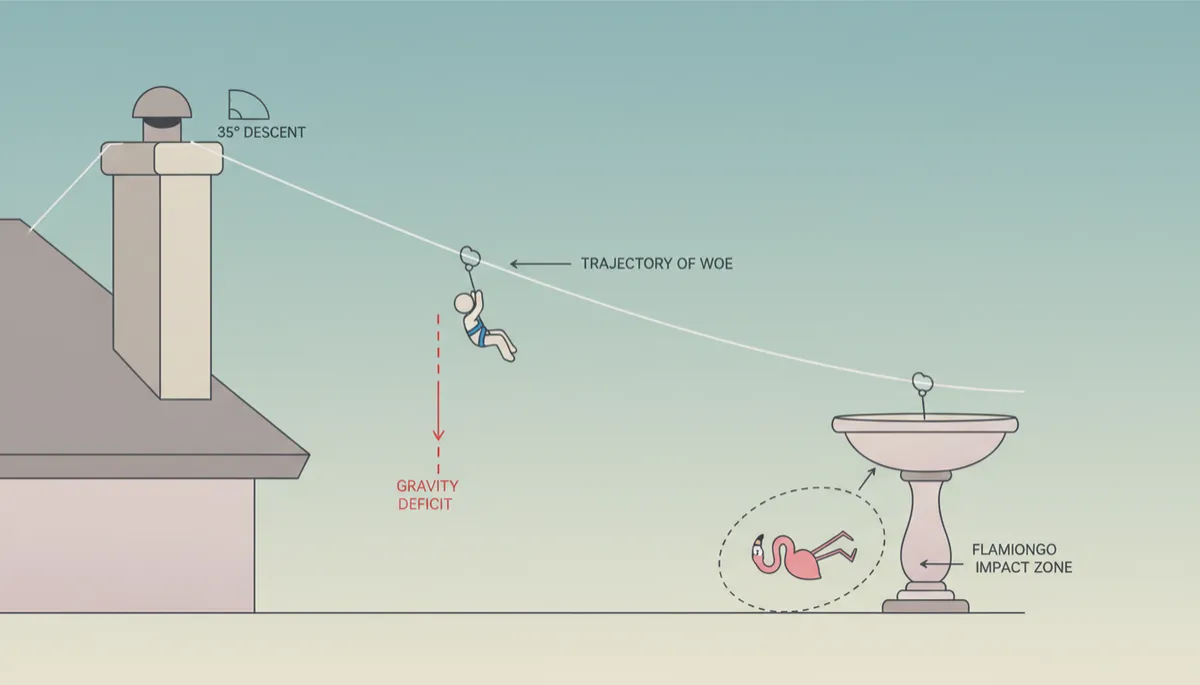
Postmortem traced 92% of anomalies to “working as improvised.”
